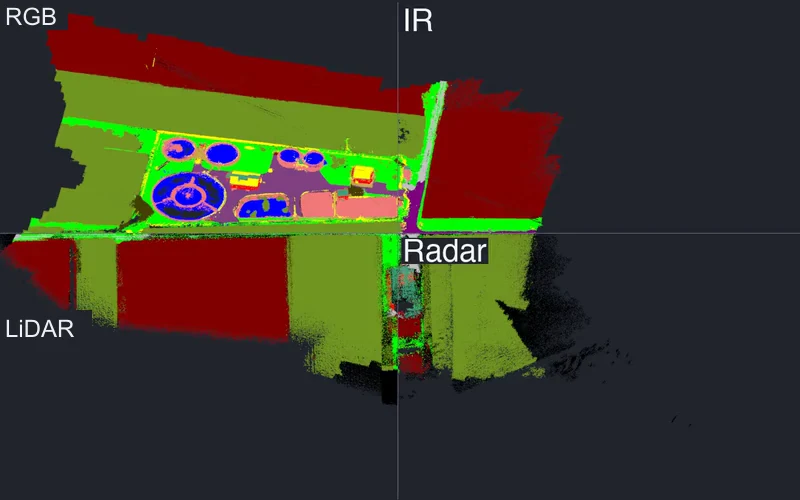
MultiFlyFour sensing modalities. One shared semantic view of the world.
A real-world aerial dataset connecting RGB, thermal, LiDAR, and radar through geometry-driven semantic label transfer.
Research / Engineering / Experiments
A collection of collaborative research and personal explorations, from perception to autonomy.
Publication record ↗Recent research
A real-world aerial dataset connecting RGB, thermal, LiDAR, and radar through geometry-driven semantic label transfer.
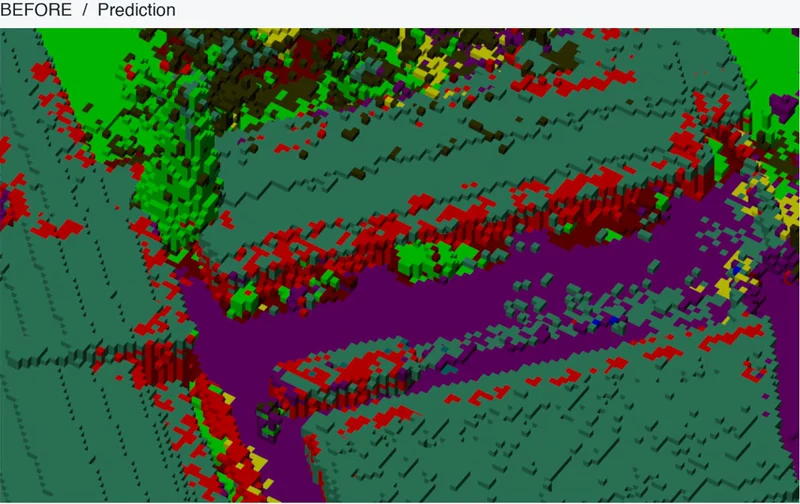
Graph-based correction of semantic labels in completed voxel maps, keeping geometry and occupancy fixed.
Mission-level evaluation of multimodal language-model agents for aerial tasks, including qualitative failure analysis.
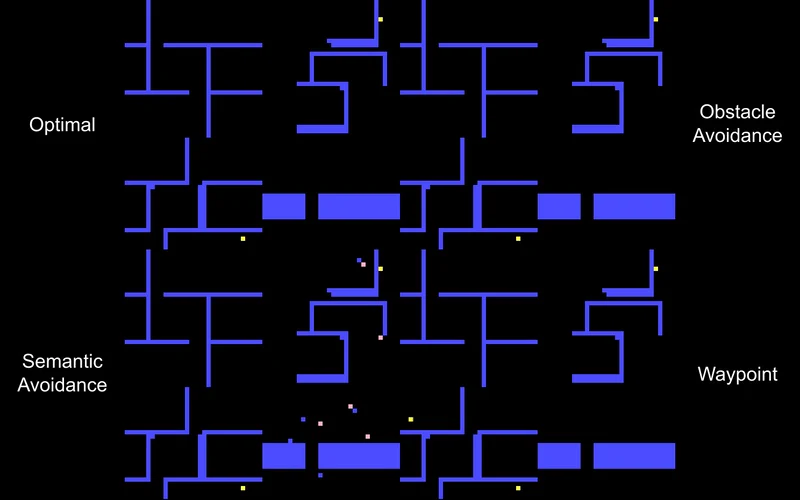
Learned semantic path priors connect image understanding with image-based planning.
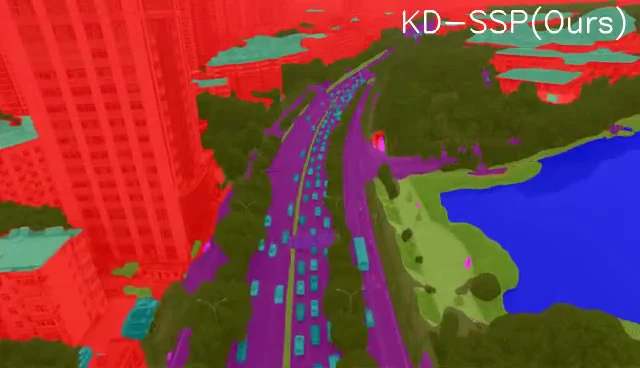
Semantic similarity propagation improves temporal consistency in video semantic segmentation for autonomous flight.
Applied research / Collaborative projects
VERUM · NiKoLaS · ADAM · ENGEL
Earlier projects / Archive
Thesis work and personal experiments in learning, control, perception, and geometry.

Master’s thesis
Exploring learned recovery strategies and their practical limits with a deep reinforcement learning controller.

Master’s thesis
An image-to-image planning framework combining supervised learning and reinforcement learning.

Personal experiment
A prototype combining mapping, track following, collision avoidance, and responses to traffic signals.

Personal experiment
Reconstructing point clouds from disparity images and turning them into 3D surface meshes.